Brazilian tow boogie

Check the top, next to USB: GND, 5V, Servo = SIG

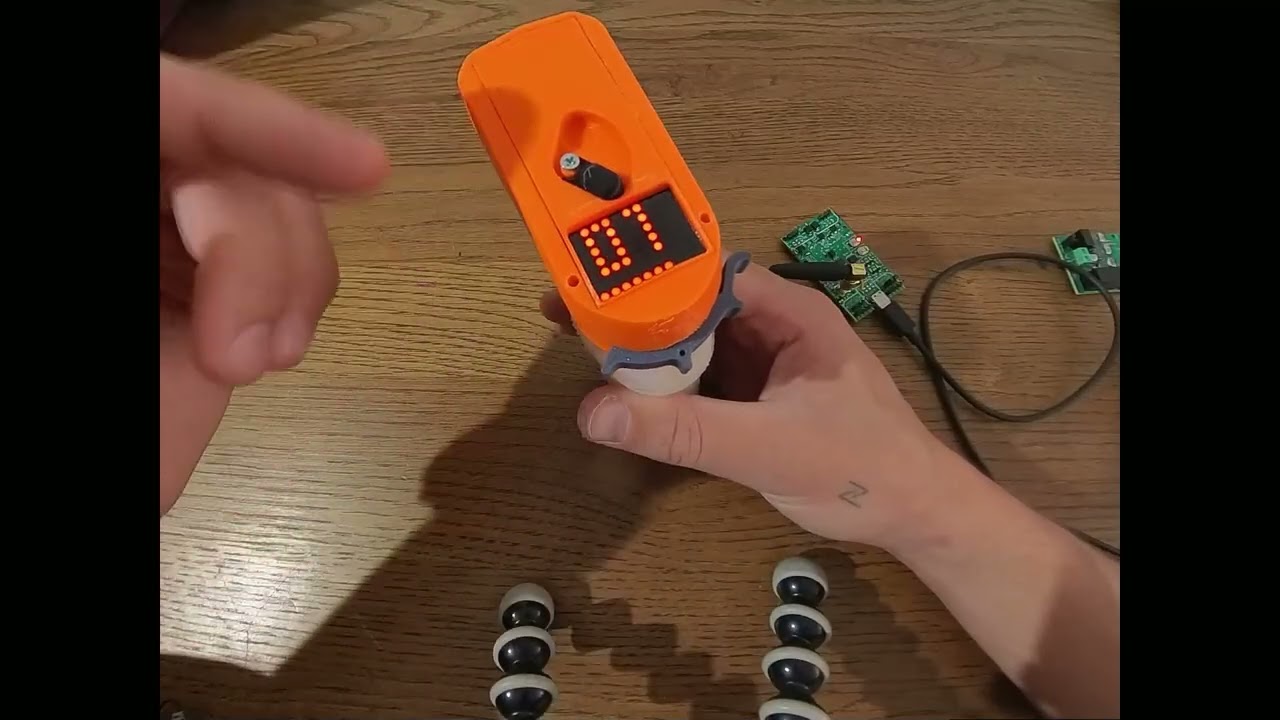
Optional, if enabled the remote will vibrate and show “E7” when there is water in the board/pelicase. Sensor is just 2 wires or metal strips next to each other (5-10mm gap), if water is between them it will detect that.

Uns meses, quando faz frio na Alemanha

Isnt it E7? :thinking: 20char

True, my bad. :man_facepalming:
E7 = Water
E8 = BMS shutoff detection

Ok, all connected now! I’m about to configure the 75200s through Vesc Project following THIS VIDEO

Does someone have the same vescs, motors and batteries as I have, and can tell if I need to be cautious with specific values?

Don’t want to do something wrong here…

The VESC in the video is the same hardware as yours, just not waterproofed, so you can use the same values
However 6384 motors won’t handle that maximum current, I think I have mine at max. of 90A

Both 75200s are built without phase filter and with firmware 5.2
Do I really need to use a newer firmware?

For eFoil there is generally no real improvement from firmware 5.x to 6.x or 7.x. I personally like to run the newest firmware but that’s up to you.

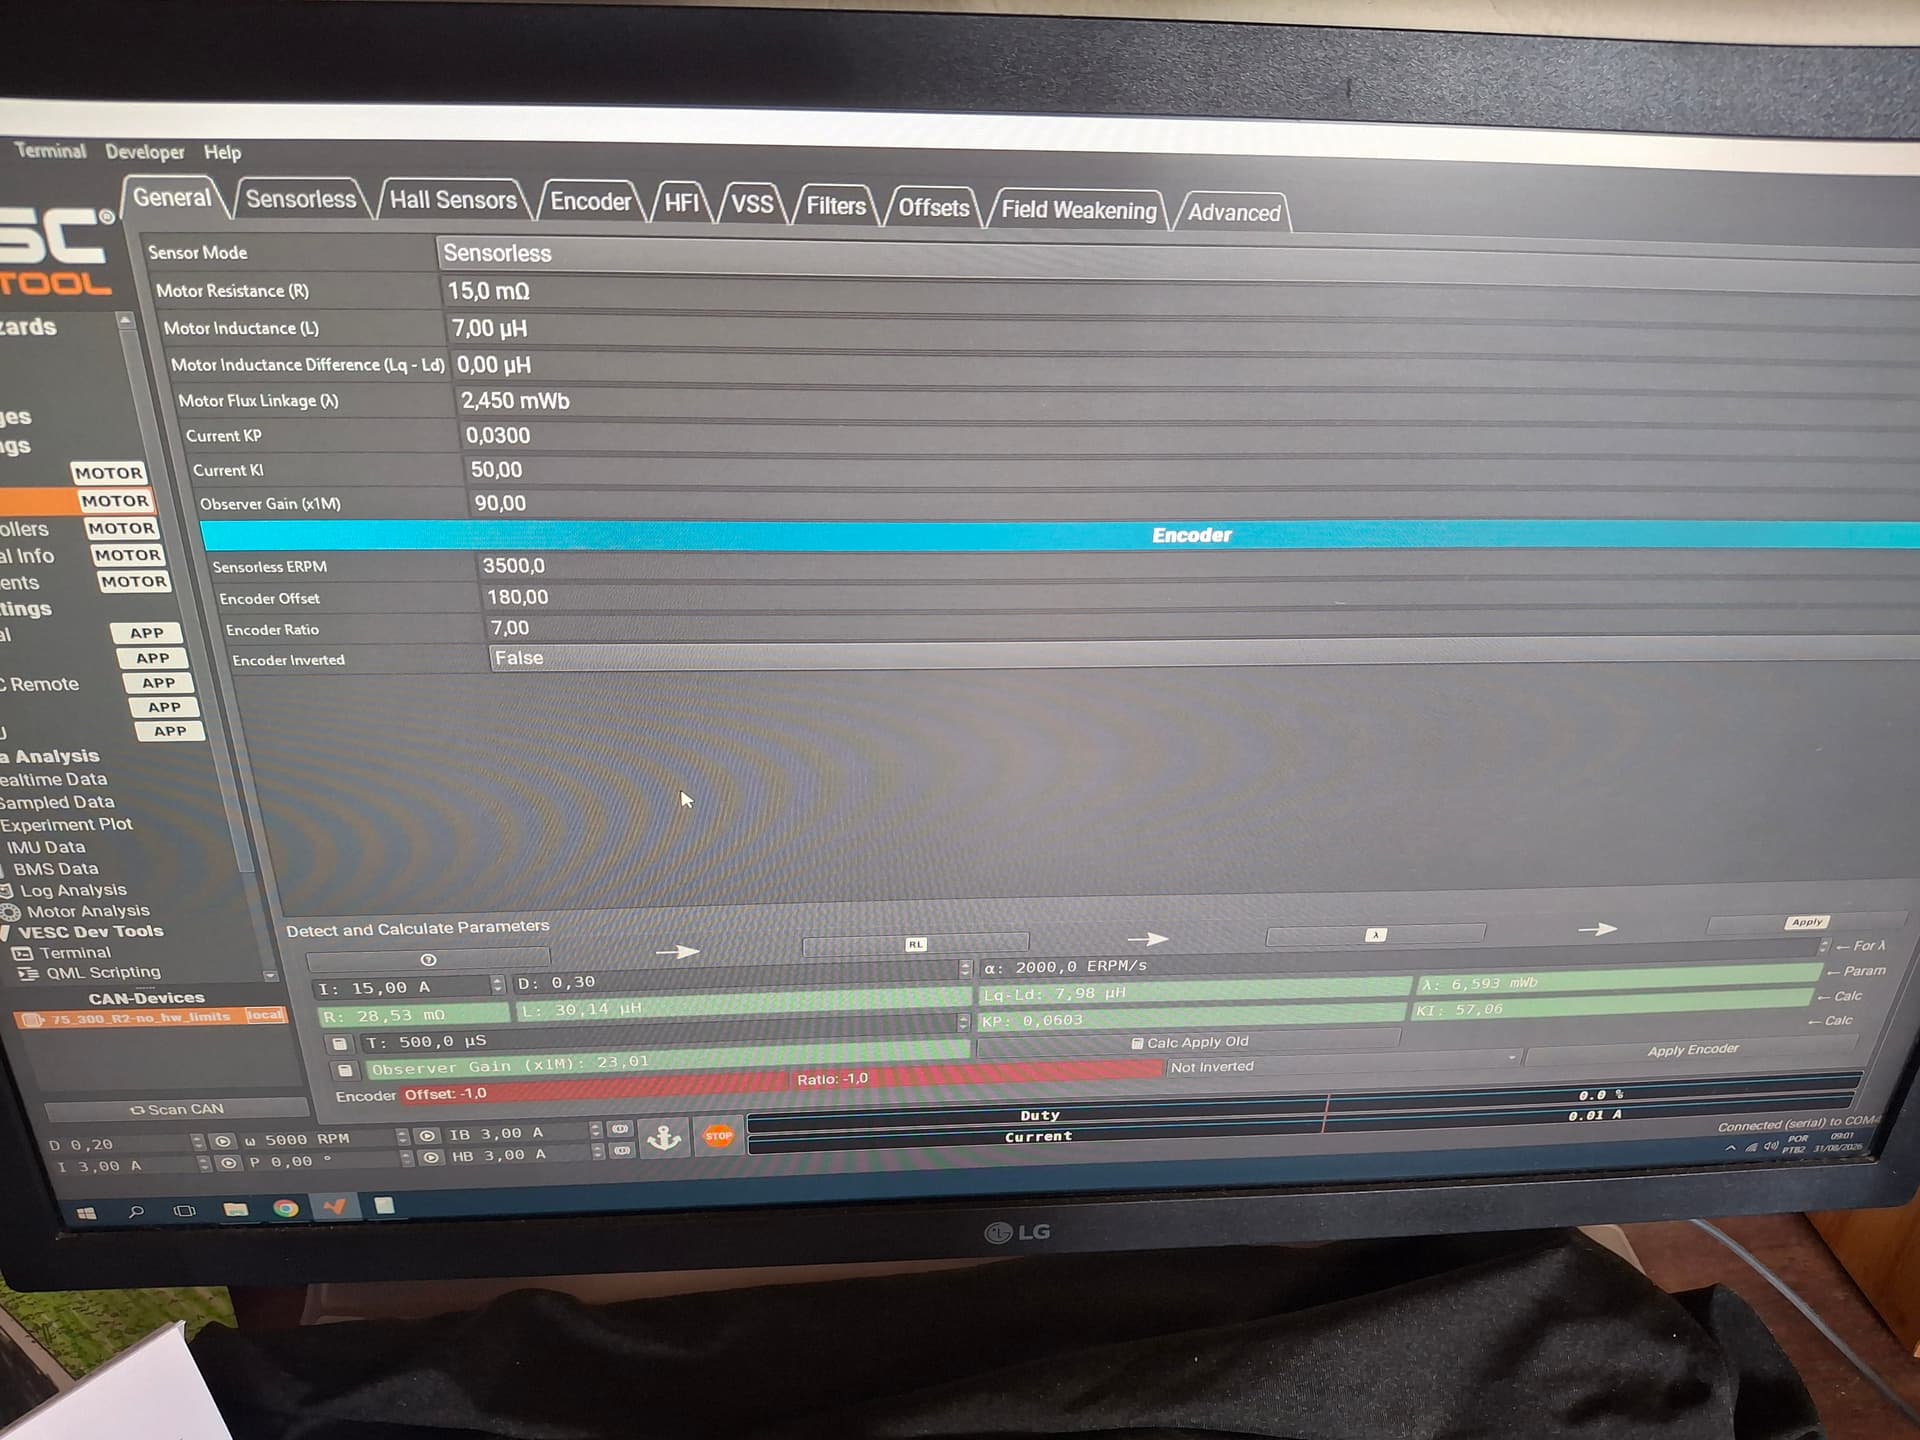
Just a question here: I have “encoder” parameters that stay red during motor detecting… what should I do?

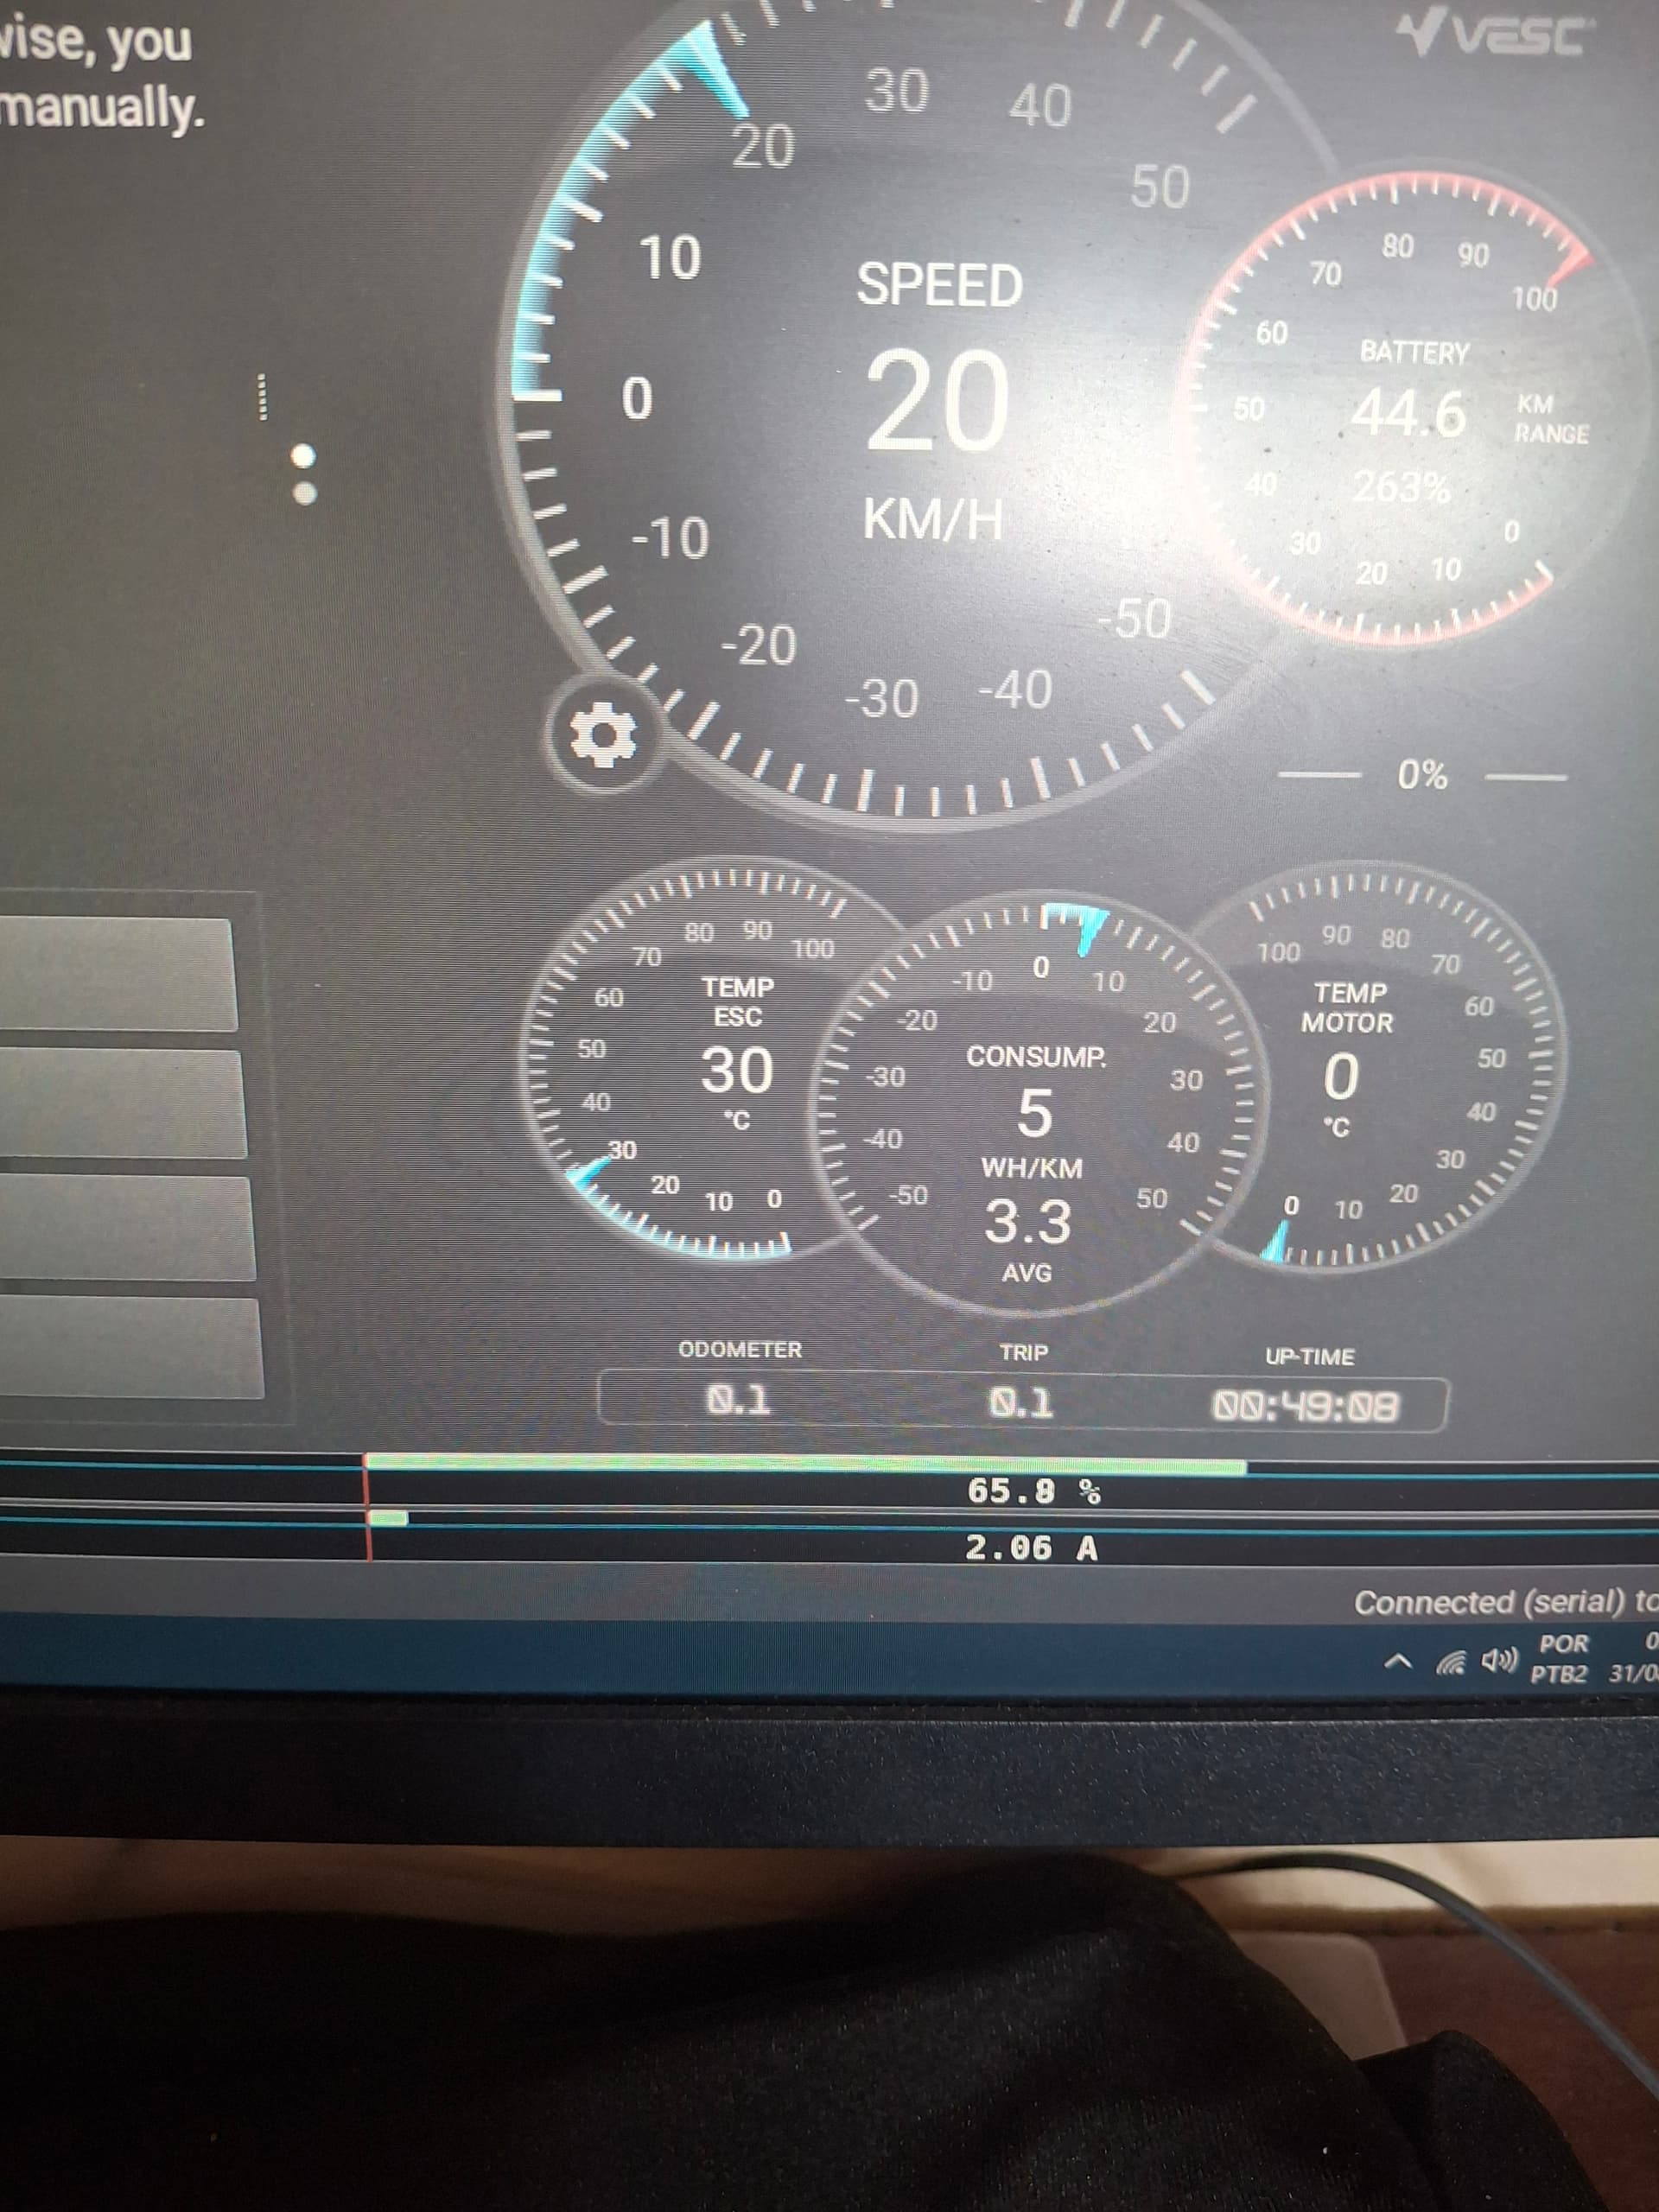
And when I test the motor is spins great but I’m stuck at 66% amps… what’s my mistake?

If you set the encoder to disabled before that’s ok

Probably incorrect remote to vesc calibration?
Make sure the remote is in the highest gear, then run input wizard like shown in my video.

If it does not help, export motor and app config as XML and share with us here

I didn’t find where to disable encoder. I only can choose “true” or “false”

I did the calibration again with remote on gear 9 and it doesn’t change… here are the xml:

4

<controller_id>87</controller_id>

<timeout_msec>1000</timeout_msec>

<timeout_brake_current>0</timeout_brake_current>

<can_status_rate_1>50</can_status_rate_1>

<can_status_rate_2>5</can_status_rate_2>

<can_status_msgs_r1>0</can_status_msgs_r1>

<can_status_msgs_r2>0</can_status_msgs_r2>

<can_baud_rate>2</can_baud_rate>

<pairing_done>0</pairing_done>

<permanent_uart_enabled>1</permanent_uart_enabled>

<shutdown_mode>7</shutdown_mode>

<can_mode>0</can_mode>

<uavcan_esc_index>0</uavcan_esc_index>

<uavcan_raw_mode>0</uavcan_raw_mode>

<uavcan_raw_rpm_max>50000</uavcan_raw_rpm_max>

<uavcan_status_current_mode>0</uavcan_status_current_mode>

<servo_out_enable>0</servo_out_enable>

<kill_sw_mode>0</kill_sw_mode>

<app_to_use>4</app_to_use>

<app_ppm_conf.ctrl_type>3</app_ppm_conf.ctrl_type>

<app_ppm_conf.pid_max_erpm>15000</app_ppm_conf.pid_max_erpm>

<app_ppm_conf.hyst>0.15</app_ppm_conf.hyst>

<app_ppm_conf.pulse_start>1</app_ppm_conf.pulse_start>

<app_ppm_conf.pulse_end>2.054</app_ppm_conf.pulse_end>

<app_ppm_conf.pulse_center>1.558</app_ppm_conf.pulse_center>

<app_ppm_conf.median_filter>1</app_ppm_conf.median_filter>

<app_ppm_conf.safe_start>1</app_ppm_conf.safe_start>

<app_ppm_conf.throttle_exp>0</app_ppm_conf.throttle_exp>

<app_ppm_conf.throttle_exp_brake>0</app_ppm_conf.throttle_exp_brake>

<app_ppm_conf.throttle_exp_mode>2</app_ppm_conf.throttle_exp_mode>

<app_ppm_conf.ramp_time_pos>0.4</app_ppm_conf.ramp_time_pos>

<app_ppm_conf.ramp_time_neg>0.2</app_ppm_conf.ramp_time_neg>

<app_ppm_conf.multi_esc>1</app_ppm_conf.multi_esc>

<app_ppm_conf.tc>0</app_ppm_conf.tc>

<app_ppm_conf.tc_max_diff>3000</app_ppm_conf.tc_max_diff>

<app_ppm_conf.max_erpm_for_dir>4000</app_ppm_conf.max_erpm_for_dir>

<app_ppm_conf.smart_rev_max_duty>0.07</app_ppm_conf.smart_rev_max_duty>

<app_ppm_conf.smart_rev_ramp_time>3</app_ppm_conf.smart_rev_ramp_time>

<app_adc_conf.ctrl_type>0</app_adc_conf.ctrl_type>

<app_adc_conf.hyst>0.15</app_adc_conf.hyst>

<app_adc_conf.voltage_start>0.9</app_adc_conf.voltage_start>

<app_adc_conf.voltage_end>3</app_adc_conf.voltage_end>

<app_adc_conf.voltage_min>0</app_adc_conf.voltage_min>

<app_adc_conf.voltage_max>3.5</app_adc_conf.voltage_max>

<app_adc_conf.voltage_center>2</app_adc_conf.voltage_center>

<app_adc_conf.voltage2_start>0.9</app_adc_conf.voltage2_start>

<app_adc_conf.voltage2_end>3</app_adc_conf.voltage2_end>

<app_adc_conf.use_filter>1</app_adc_conf.use_filter>

<app_adc_conf.safe_start>1</app_adc_conf.safe_start>

<app_adc_conf.buttons>0</app_adc_conf.buttons>

<app_adc_conf.voltage_inverted>0</app_adc_conf.voltage_inverted>

<app_adc_conf.voltage2_inverted>0</app_adc_conf.voltage2_inverted>

<app_adc_conf.throttle_exp>0</app_adc_conf.throttle_exp>

<app_adc_conf.throttle_exp_brake>0</app_adc_conf.throttle_exp_brake>

<app_adc_conf.throttle_exp_mode>2</app_adc_conf.throttle_exp_mode>

<app_adc_conf.ramp_time_pos>0.3</app_adc_conf.ramp_time_pos>

<app_adc_conf.ramp_time_neg>0.1</app_adc_conf.ramp_time_neg>

<app_adc_conf.multi_esc>1</app_adc_conf.multi_esc>

<app_adc_conf.tc>0</app_adc_conf.tc>

<app_adc_conf.tc_max_diff>3000</app_adc_conf.tc_max_diff>

<app_adc_conf.update_rate_hz>500</app_adc_conf.update_rate_hz>

<app_uart_baudrate>115200</app_uart_baudrate>

<app_chuk_conf.ctrl_type>0</app_chuk_conf.ctrl_type>

<app_chuk_conf.hyst>0.15</app_chuk_conf.hyst>

<app_chuk_conf.ramp_time_pos>0.4</app_chuk_conf.ramp_time_pos>

<app_chuk_conf.ramp_time_neg>0.2</app_chuk_conf.ramp_time_neg>

<app_chuk_conf.stick_erpm_per_s_in_cc>3000</app_chuk_conf.stick_erpm_per_s_in_cc>

<app_chuk_conf.throttle_exp>0</app_chuk_conf.throttle_exp>

<app_chuk_conf.throttle_exp_brake>0</app_chuk_conf.throttle_exp_brake>

<app_chuk_conf.throttle_exp_mode>2</app_chuk_conf.throttle_exp_mode>

<app_chuk_conf.multi_esc>1</app_chuk_conf.multi_esc>

<app_chuk_conf.tc>0</app_chuk_conf.tc>

<app_chuk_conf.tc_max_diff>3000</app_chuk_conf.tc_max_diff>

<app_chuk_conf.use_smart_rev>1</app_chuk_conf.use_smart_rev>

<app_chuk_conf.smart_rev_max_duty>0.07</app_chuk_conf.smart_rev_max_duty>

<app_chuk_conf.smart_rev_ramp_time>3</app_chuk_conf.smart_rev_ramp_time>

<app_chuk_conf.coast_brake_level>0</app_chuk_conf.coast_brake_level>

<app_chuk_conf.coast_brake_ramp_time>1</app_chuk_conf.coast_brake_ramp_time>

<app_nrf_conf.speed>1</app_nrf_conf.speed>

<app_nrf_conf.power>3</app_nrf_conf.power>

<app_nrf_conf.crc_type>1</app_nrf_conf.crc_type>

<app_nrf_conf.retry_delay>0</app_nrf_conf.retry_delay>

<app_nrf_conf.retries>3</app_nrf_conf.retries>

<app_nrf_conf.channel>76</app_nrf_conf.channel>

<app_nrf_conf.address__0>198</app_nrf_conf.address__0>

<app_nrf_conf.address__1>199</app_nrf_conf.address__1>

<app_nrf_conf.address__2>0</app_nrf_conf.address__2>

<app_nrf_conf.send_crc_ack>1</app_nrf_conf.send_crc_ack>

<app_pas_conf.ctrl_type>0</app_pas_conf.ctrl_type>

<app_pas_conf.sensor_type>0</app_pas_conf.sensor_type>

<app_pas_conf.pedal_rpm_start>10</app_pas_conf.pedal_rpm_start>

<app_pas_conf.pedal_rpm_end>180</app_pas_conf.pedal_rpm_end>

<app_pas_conf.invert_pedal_direction>0</app_pas_conf.invert_pedal_direction>

<app_pas_conf.magnets>24</app_pas_conf.magnets>

<app_pas_conf.use_filter>1</app_pas_conf.use_filter>

<app_pas_conf.current_scaling>0.1</app_pas_conf.current_scaling>

<app_pas_conf.ramp_time_pos>0.6</app_pas_conf.ramp_time_pos>

<app_pas_conf.ramp_time_neg>0.3</app_pas_conf.ramp_time_neg>

<app_pas_conf.update_rate_hz>500</app_pas_conf.update_rate_hz>

<imu_conf.type>1</imu_conf.type>

<imu_conf.mode>0</imu_conf.mode>

<imu_conf.filter>1</imu_conf.filter>

<imu_conf.accel_lowpass_filter_x>0</imu_conf.accel_lowpass_filter_x>

<imu_conf.accel_lowpass_filter_y>0</imu_conf.accel_lowpass_filter_y>

<imu_conf.accel_lowpass_filter_z>0</imu_conf.accel_lowpass_filter_z>

<imu_conf.gyro_lowpass_filter>0</imu_conf.gyro_lowpass_filter>

<imu_conf.sample_rate_hz>200</imu_conf.sample_rate_hz>

<imu_conf.use_magnetometer>1</imu_conf.use_magnetometer>

<imu_conf.accel_confidence_decay>1</imu_conf.accel_confidence_decay>

<imu_conf.mahony_kp>0.3</imu_conf.mahony_kp>

<imu_conf.mahony_ki>0</imu_conf.mahony_ki>

<imu_conf.madgwick_beta>0.1</imu_conf.madgwick_beta>

<imu_conf.rot_roll>0</imu_conf.rot_roll>

<imu_conf.rot_pitch>0</imu_conf.rot_pitch>

<imu_conf.rot_yaw>0</imu_conf.rot_yaw>

<imu_conf.accel_offsets__0>0</imu_conf.accel_offsets__0>

<imu_conf.accel_offsets__1>0</imu_conf.accel_offsets__1>

<imu_conf.accel_offsets__2>0</imu_conf.accel_offsets__2>

<imu_conf.gyro_offsets__0>0</imu_conf.gyro_offsets__0>

<imu_conf.gyro_offsets__1>0</imu_conf.gyro_offsets__1>

<imu_conf.gyro_offsets__2>0</imu_conf.gyro_offsets__2>

4

<pwm_mode>1</pwm_mode>

<comm_mode>0</comm_mode>

<motor_type>2</motor_type>

<sensor_mode>0</sensor_mode>

<l_current_max>75</l_current_max>

<l_current_min>-20</l_current_min>

<l_in_current_max>150</l_in_current_max>

<l_in_current_min>-20</l_in_current_min>

<l_in_current_map_start>0.9</l_in_current_map_start>

<l_in_current_map_filter>0.002</l_in_current_map_filter>

<l_abs_current_max>100</l_abs_current_max>

<l_min_erpm>-27000</l_min_erpm>

<l_max_erpm>27000</l_max_erpm>

<l_erpm_start>0.8</l_erpm_start>

<l_max_erpm_fbrake>300</l_max_erpm_fbrake>

<l_max_erpm_fbrake_cc>1500</l_max_erpm_fbrake_cc>

<l_min_vin>12</l_min_vin>

<l_max_vin>50</l_max_vin>

<l_battery_cut_start>36</l_battery_cut_start>

<l_battery_cut_end>32</l_battery_cut_end>

<l_battery_regen_cut_start>1000</l_battery_regen_cut_start>

<l_battery_regen_cut_end>1100</l_battery_regen_cut_end>

<l_slow_abs_current>0</l_slow_abs_current>

<l_temp_fet_start>85</l_temp_fet_start>

<l_temp_fet_end>100</l_temp_fet_end>

<l_temp_motor_start>85</l_temp_motor_start>

<l_temp_motor_end>100</l_temp_motor_end>

<l_temp_accel_dec>0.15</l_temp_accel_dec>

<l_min_duty>0.005</l_min_duty>

<l_max_duty>0.95</l_max_duty>

<l_watt_max>1.5e+06</l_watt_max>

<l_watt_min>-1.5e+06</l_watt_min>

<l_current_max_scale>1</l_current_max_scale>

<l_current_min_scale>1</l_current_min_scale>

<l_duty_start>1</l_duty_start>

<l_additional_faults>0</l_additional_faults>

<sl_min_erpm>150</sl_min_erpm>

<sl_min_erpm_cycle_int_limit>1100</sl_min_erpm_cycle_int_limit>

<sl_max_fullbreak_current_dir_change>10</sl_max_fullbreak_current_dir_change>

<sl_cycle_int_limit>62</sl_cycle_int_limit>

<sl_phase_advance_at_br>0.8</sl_phase_advance_at_br>

<sl_cycle_int_rpm_br>80000</sl_cycle_int_rpm_br>

<sl_bemf_coupling_k>600</sl_bemf_coupling_k>

<hall_table__0>-1</hall_table__0>

<hall_table__1>1</hall_table__1>

<hall_table__2>3</hall_table__2>

<hall_table__3>2</hall_table__3>

<hall_table__4>5</hall_table__4>

<hall_table__5>6</hall_table__5>

<hall_table__6>4</hall_table__6>

<hall_table__7>-1</hall_table__7>

<hall_sl_erpm>2000</hall_sl_erpm>

<foc_current_kp>0.0602</foc_current_kp>

<foc_current_ki>57.32</foc_current_ki>

<foc_f_zv>30000</foc_f_zv>

<foc_dt_us>0.12</foc_dt_us>

<foc_encoder_inverted>0</foc_encoder_inverted>

<foc_encoder_offset>180</foc_encoder_offset>

<foc_encoder_ratio>7</foc_encoder_ratio>

<foc_sensor_mode>0</foc_sensor_mode>

<foc_pll_kp>2000</foc_pll_kp>

<foc_pll_ki>30000</foc_pll_ki>

<foc_motor_l>3.01e-05</foc_motor_l>

<foc_motor_ld_lq_diff>1.169e-05</foc_motor_ld_lq_diff>

<foc_motor_r>0.0287</foc_motor_r>

<foc_motor_flux_linkage>0.006439</foc_motor_flux_linkage>

<foc_observer_gain>2.412e+07</foc_observer_gain>

<foc_observer_gain_slow>0.05</foc_observer_gain_slow>

<foc_observer_offset>-1</foc_observer_offset>

<foc_duty_dowmramp_kp>20</foc_duty_dowmramp_kp>

<foc_duty_dowmramp_ki>400</foc_duty_dowmramp_ki>

<foc_start_curr_dec>1</foc_start_curr_dec>

<foc_start_curr_dec_rpm>2500</foc_start_curr_dec_rpm>

<foc_openloop_rpm>1500</foc_openloop_rpm>

<foc_openloop_rpm_low>0</foc_openloop_rpm_low>

<foc_sl_openloop_hyst>0.1</foc_sl_openloop_hyst>

<foc_sl_openloop_time_lock>0</foc_sl_openloop_time_lock>

<foc_sl_openloop_time_ramp>0.1</foc_sl_openloop_time_ramp>

<foc_sl_openloop_time>0.05</foc_sl_openloop_time>

<foc_sl_openloop_boost_q>0</foc_sl_openloop_boost_q>

<foc_sl_openloop_max_q>-1</foc_sl_openloop_max_q>

<foc_hall_table__0>255</foc_hall_table__0>

<foc_hall_table__1>255</foc_hall_table__1>

<foc_hall_table__2>255</foc_hall_table__2>

<foc_hall_table__3>255</foc_hall_table__3>

<foc_hall_table__4>255</foc_hall_table__4>

<foc_hall_table__5>255</foc_hall_table__5>

<foc_hall_table__6>255</foc_hall_table__6>

<foc_hall_table__7>255</foc_hall_table__7>

<foc_hall_interp_erpm>500</foc_hall_interp_erpm>

<foc_sl_erpm_start>2500</foc_sl_erpm_start>

<foc_sl_erpm>3500</foc_sl_erpm>

<foc_control_sample_mode>0</foc_control_sample_mode>

<foc_current_sample_mode>0</foc_current_sample_mode>

<foc_sat_comp_mode>0</foc_sat_comp_mode>

<foc_sat_comp>0</foc_sat_comp>

<foc_temp_comp>0</foc_temp_comp>

<foc_temp_comp_base_temp>25</foc_temp_comp_base_temp>

<foc_current_filter_const>0.1</foc_current_filter_const>

<foc_cc_decoupling>0</foc_cc_decoupling>

<foc_observer_type>3</foc_observer_type>

<foc_hfi_amb_mode>0</foc_hfi_amb_mode>

<foc_hfi_amb_current>60</foc_hfi_amb_current>

<foc_hfi_amb_tres>15</foc_hfi_amb_tres>

<foc_hfi_voltage_start>20</foc_hfi_voltage_start>

<foc_hfi_voltage_run>4</foc_hfi_voltage_run>

<foc_hfi_voltage_max>6</foc_hfi_voltage_max>

<foc_hfi_gain>0.3</foc_hfi_gain>

<foc_hfi_max_err>0.3</foc_hfi_max_err>

<foc_hfi_hyst>0</foc_hfi_hyst>

<foc_sl_erpm_hfi>3000</foc_sl_erpm_hfi>

<foc_hfi_reset_erpm>500</foc_hfi_reset_erpm>

<foc_hfi_start_samples>5</foc_hfi_start_samples>

<foc_hfi_obs_ovr_sec>0.001</foc_hfi_obs_ovr_sec>

<foc_hfi_samples>1</foc_hfi_samples>

<foc_offsets_cal_mode>1</foc_offsets_cal_mode>

<foc_offsets_current__0>2016.79</foc_offsets_current__0>

<foc_offsets_current__1>2018.99</foc_offsets_current__1>

<foc_offsets_current__2>2013.89</foc_offsets_current__2>

<foc_offsets_voltage__0>0.0014</foc_offsets_voltage__0>

<foc_offsets_voltage__1>-0.0009</foc_offsets_voltage__1>

<foc_offsets_voltage__2>-0.0004</foc_offsets_voltage__2>

<foc_offsets_voltage_undriven__0>0</foc_offsets_voltage_undriven__0>

<foc_offsets_voltage_undriven__1>0</foc_offsets_voltage_undriven__1>

<foc_offsets_voltage_undriven__2>0</foc_offsets_voltage_undriven__2>

<foc_phase_filter_enable>0</foc_phase_filter_enable>

<foc_phase_filter_disable_fault>1</foc_phase_filter_disable_fault>

<foc_phase_filter_max_erpm>4000</foc_phase_filter_max_erpm>

<foc_mtpa_mode>0</foc_mtpa_mode>

<foc_fw_current_max>0</foc_fw_current_max>

<foc_fw_duty_start>0.8</foc_fw_duty_start>

<foc_fw_q_current_factor>0.05</foc_fw_q_current_factor>

<foc_fw_backoff>2</foc_fw_backoff>

<foc_fw_ramp_time>0</foc_fw_ramp_time>

<foc_speed_soure>0</foc_speed_soure>

<foc_short_ls_on_zero_duty>0</foc_short_ls_on_zero_duty>

<foc_overmod_factor>1</foc_overmod_factor>

<foc_mag_vd_max>0.98</foc_mag_vd_max>

<sp_pid_loop_rate>5</sp_pid_loop_rate>

<s_pid_kp>0.004</s_pid_kp>

<s_pid_ki>0.004</s_pid_ki>

<s_pid_kd>0.0001</s_pid_kd>

<s_pid_kd_filter>0.2</s_pid_kd_filter>

<s_pid_min_erpm>900</s_pid_min_erpm>

<s_pid_allow_braking>1</s_pid_allow_braking>

<s_pid_ramp_erpms_s>25000</s_pid_ramp_erpms_s>

<s_pid_speed_source>0</s_pid_speed_source>

<p_pid_kp>0.025</p_pid_kp>

<p_pid_ki>0</p_pid_ki>

<p_pid_kd>0</p_pid_kd>

<p_pid_offset>0</p_pid_offset>

<p_pid_kd_proc>0.00035</p_pid_kd_proc>

<p_pid_kd_filter>0.2</p_pid_kd_filter>

<p_pid_ang_div>1</p_pid_ang_div>

<p_pid_gain_dec_angle>0</p_pid_gain_dec_angle>

<cc_startup_boost_duty>0.01</cc_startup_boost_duty>

<cc_min_current>0.05</cc_min_current>

<cc_gain>0.0046</cc_gain>

<cc_ramp_step_max>0.04</cc_ramp_step_max>

<m_fault_stop_time_ms>500</m_fault_stop_time_ms>

<m_duty_ramp_step>0.02</m_duty_ramp_step>

<m_current_backoff_gain>0.5</m_current_backoff_gain>

<m_encoder_counts>8192</m_encoder_counts>

<m_encoder_sin_amp>1</m_encoder_sin_amp>

<m_encoder_cos_amp>1</m_encoder_cos_amp>

<m_encoder_sin_offset>1.65</m_encoder_sin_offset>

<m_encoder_cos_offset>1.65</m_encoder_cos_offset>

<m_encoder_sincos_filter_constant>0.5</m_encoder_sincos_filter_constant>

<m_encoder_sincos_phase_correction>0</m_encoder_sincos_phase_correction>

<m_sensor_port_mode>0</m_sensor_port_mode>

<m_invert_direction>0</m_invert_direction>

<m_drv8301_oc_mode>0</m_drv8301_oc_mode>

<m_drv8301_oc_adj>16</m_drv8301_oc_adj>

<m_bldc_f_sw_min>3000</m_bldc_f_sw_min>

<m_bldc_f_sw_max>35000</m_bldc_f_sw_max>

<m_dc_f_sw>25000</m_dc_f_sw>

<m_ntc_motor_beta>3380</m_ntc_motor_beta>

<m_out_aux_mode>0</m_out_aux_mode>

<m_motor_temp_sens_type>8</m_motor_temp_sens_type>

<m_ptc_motor_coeff>0.61</m_ptc_motor_coeff>

<m_ntcx_ptcx_res>10000</m_ntcx_ptcx_res>

<m_ntcx_ptcx_temp_base>25</m_ntcx_ptcx_temp_base>

<m_hall_extra_samples>3</m_hall_extra_samples>

<m_batt_filter_const>45</m_batt_filter_const>

<si_motor_poles>14</si_motor_poles>

<si_gear_ratio>3</si_gear_ratio>

<si_wheel_diameter>0.083</si_wheel_diameter>

<si_battery_type>0</si_battery_type>

<si_battery_cells>12</si_battery_cells>

<si_battery_ah>6</si_battery_ah>

<si_motor_nl_current>1</si_motor_nl_current>

<motor_brand/>

<motor_model/>

<motor_weight>0</motor_weight>

<motor_sensor_type>0</motor_sensor_type>

<motor_description/>

<motor_quality_bearings>0</motor_quality_bearings>

<motor_quality_magnets>0</motor_quality_magnets>

<motor_quality_construction>0</motor_quality_construction>

<motor_quality_description/>

<bms.type>0</bms.type>

<bms.limit_mode>3</bms.limit_mode>

<bms.t_limit_start>45</bms.t_limit_start>

<bms.t_limit_end>65</bms.t_limit_end>

<bms.soc_limit_start>0.05</bms.soc_limit_start>

<bms.soc_limit_end>0</bms.soc_limit_end>

<bms.vmin_limit_start>2.9</bms.vmin_limit_start>

<bms.vmin_limit_end>2.5</bms.vmin_limit_end>

<bms.vmax_limit_start>4.2</bms.vmax_limit_start>

<bms.vmax_limit_end>4.3</bms.vmax_limit_end>

<bms.fwd_can_mode>0</bms.fwd_can_mode>

The erpm may be the limit
For 140kV 7-pole motor at 12s that should roughly be 40.000-50.000, not 27.000
Or just don’t limit it at all (set 100.000), since the limit is not really needed in your case

Ok it works @38000 RPM now and goes until +/- 93% duty which is fine I guess. For some reason it doesn’t work anymore if I go beyond 38000 RPM, in that case when I go full throttle the motors start to spin then immediately stop.

Also Ludwig how does the differential control works? The left&right trigger has no action, both motors keep spinning exactly the same…

Did you enable steering both in Tx and Rx settings?

Not at all :joy:
It seems I need more youtube videos and forum reading…

22:40 until the end explains the Settings of Tx and Rx

Ok, it appears that steering was enabled in TX but not in RX. I also changed frequency to 915MHz and RF power to 20 on both.

String for TX:

AgACABQAAQBkAKM/syhCK+0ymzf0AR4A9AGIE9AHZADoAwoA0AcAAAAACgAAAAEAMgAAADIAAABDrkI5AAAAAAAAAADoAwEAXYysRs3QAAA=

String for RX:

AgACABQAAQAyAAAAAADcBdAH3AXQB+gDDAAAAAEAAAACAAEAAAAAAAAAyEEAACBBAAAgQQAAoEAAAAxCAAA0QgAANEJBjhw8AAAAAOgDAQABAEbN0F2MrA==

After that the motors would not react good so I did the FOC parameters again and it is now good, steering does seem to work even if it’s hard to say exactly out of the water just earing motors…

Is the external antenna reception strong enough to be mounted on top of the PeliCase, even if I plan to cover the tow boogie with a removable flexible “cap” (and so will be the antenna) ?