I will post below with all the things I have learned from messing around with my flipsky vesc over the last year as this may help you and others with similar issues.
However, I would add that you cant really avoid the reading with this stuff (I see that you just joined the forum and are only at 10mins reading time). There is so much info on this forum that you need to spend 10+ hours just to get your head around it - the acronyms will become clearer (or look them up on google).
The other forum that is very useful is https://forum.esk8.news/.
(I would recommend this post for Flipsky firmware issues How to update firmware on the Flipsky 75100 & 75200 FOC ESC - The Citadel - Essential References for Esk8 - esk8.news: DIY Electric Skateboard Forums).
What have I learned from many hours messing around with FLIPSKY 75200 V1 Vesc :
(in no particular order)
- In terms of firmware have gone for FSESC_75_200_ALU default (recommended by Jaykup on Esk8 forum) despite Flipsky (Ariel) saying to use 75_300 (non R2 version). This one seems quite stable and good so far. It appears to have eliminated the problems of USB connection “freezing” that I was having previously.
- When running Wizard, it does not seem to matter whether use Medium or Large inrunner
- I have not been able to get FOC to work smoothly – I still had some cogging at start and when pulling trigger fully in one go get nasty noises. So its BLDC (sensorless) all the way for me (slightly noisier but much smoother)
- HFI (in FOC mode) – I can’t get this to do anything useful. It seems the inductance gap of the motor is too small (<5%) and the HFI makes a noise all the time, not just when you pull the trigger, despite following tuto on Esk8 forum (VESC-Tool 2.0 and Firmware 4.0 - The beginning of a new era - (SERIOUS) - #195 by Deodand - esk8.news: DIY Electric Skateboard Forums).
- Not too sure where to set max motor current, ABS current and Bat current but have set to 170, 200 and 120 respectively and seems ok. I have not gone above 86A Bat current and 120 motor current in my last run at full throttle and most of the time was at around 25A Bat current when foiling.
- I have set maximum wattage to 5000 as this is a bit below motor specs – this will probably limit battery current to around 86 amps anyway (@58 volts).
- I have reduce default temperature limits by about 4 degrees on all indicators for good measure.
- I have set max Duty Cylce to 80% to limit top speed and to be able to go (near) full trigger for flying (I will need to adjust this as I get more log data – Motor Settings/General/Advanced)
- I have set minimum current to 0.8A as this seems to give better startup
- On App settings I have set input deadband to 5% and throttle curve to Polynomial (no adjustment) to get a snappier and smoother trigger action.
- For the controller (Flipsky VX3) I am using PPM mode as I need the UART1 port for the flipsky BLE module for logging and the UART2 port on my version, does not support bluetooth (confirmed by Flipsky). I have noticed that the PPM seems to have a slightly faster response than UART but of course you loose almost all of the real time telemetry data on the controller.
- As far as I can remember, all of the other settings are left at default values (except of course turning OFF the phase filtering in FOC mode to avoid destroying the motor according to Flipsky).
One issue I am still trying to figure out is how to get GPS data with the vesc logs - I get all the other info, but for some reason the GPS from my phone does not seem to be captured. Any ideas on this would be appreciated !
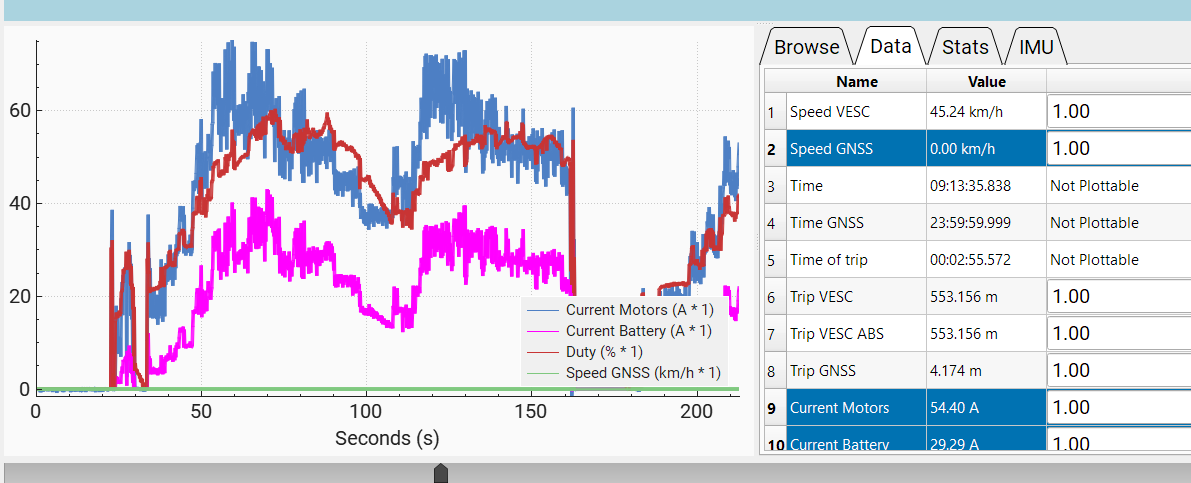
As a final note, I have not really figured out what the L, M, and H setting on the VX3 actually change - for example in PPM mode, do L and M modes reduce the maximum pulse width ? With my latest testing it seems I can still fly even in L mode with full throttle (this was not the case before when I was using UART mode but I have made many changes so it may be something else). However, it seems to require more current and power to fly in L mode that in H mode so something strange is going on here which I need to investigate further.